


Cryptide ResearchAutonomous Mobile Robot (AMR)Turnkey sim-to-real robotics on NVIDIA Jetson, shipped to every car with Avocado OS
- Company
- Cryptide Research
- Product
- GOAT Racer 3
- Use case
- Turnkey sim-to-real robotics
- Hardware
- NVIDIA Jetson Orin Nano 8GB
- Status
- Shipping
A member of the Avocado Design Program, built alongside Peridio engineering.
- To provision a carDown from about 3 hours
- 10 min
- Per policy update, over the airOne ONNX file, sent to one car
- ~400 KB
- Of uptime across policy updatesWas a reboot on every update
- Days
The company
From a master’s project to a sim-to-real platform
Cryptide Research builds GOAT Racer 3, an autonomous 1/10-scale race car for teams getting started with physical AI. Train a driving policy in NVIDIA Isaac Lab and race it on NVIDIA Jetson the same day.
GOAT Racer 3 grew out of Rob Murrer’s master’s project. Rob spent a decade in electronic design automation and RF before moving into robotics, and he wanted a sim-to-real platform he could put in other people’s hands. Nothing off the shelf fit, so he built one.
Users work through a web interface that hides the training infrastructure. Each one trains a policy, checks it in simulation and sends it to their own car.
A policy is the trained neural network that drives the car. It reads what the sensors see and decides how to steer and how much throttle to give.
Explore the GOAT Racer 3 course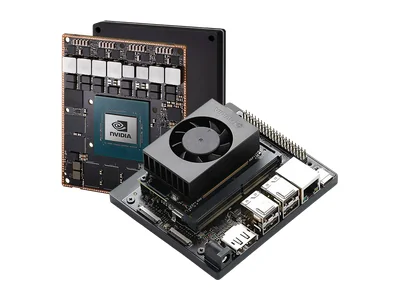
Compute
NVIDIA Jetson Orin Nano 8GB
Perception
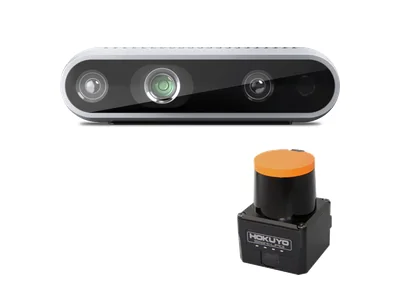
Intel RealSense depth camera + LiDAR
Control
Sensored motor with hall-effect feedback
Safety
Remote kill switch + teleop
GOAT Racer 3 · Turnkey sim-to-real robotics
A real car you can test at low speed
The car recreates the F1TENTH project, known inside NVIDIA as Project Leatherback. A sensored motor gives precise control at low speed, so a policy gets validated slowly before the car ramps up.
The challenge
The wall at three Jetson race cars
1 car
One car on JetPack
JetPack got the first car running fast. The Cryptide Research team still calls it the right starting point: a full desktop environment where you install anything and iterate quickly.
2 cars
Two cars, scripts and Docker
A shell script brought up the base OS, then a large Docker container shipped on top. The team spent hours optimizing container layers so rebuilds wouldn’t drag.
3 cars
Three cars, and the drift starts
Provisioning meant NVIDIA SDK Manager on a dedicated Ubuntu host, about three hours per car. Versions drifted, updates landed inconsistently, and in workshops the recurring question was which robot had the best policy on it.
Avocado OS
Every car on Avocado OS
Cryptide Research provisions every GOAT Racer 3 before it ships, so each one boots onto the same deterministic, reproducible OS. OS, app and policy updates go out over the air through Peridio in seconds.
In the field, determinism matters. A product only feels good to use if it behaves the same way on every unit, every time, and a company’s reputation depends on it.
“When I ship an update, the rest of the robot stays completely functional. Only the policy changes. I’ve had these robots up for days without a reboot.”
Why Avocado OS
Why Cryptide Research chose Avocado OS
The Cryptide Research team weighed three ways to put an OS on the fleet.
| Custom Yocto build | Container-first platform | Avocado OS | |
|---|---|---|---|
| Same base on every car | Yes, reproducible | No, the image is mutated in the field | Yes, deterministic and locked down |
| Who builds the OS | The team, with long compiles | Whoever rebuilds the image | Built on Yocto and NVIDIA’s Jetson support; nothing to compile |
| Ongoing upkeep | More than a small team could carry | One large image to keep optimizing | The base stays fixed |
| What changes on a car | A rebuilt image | The whole container | An extension, like a driving policy |
“Avocado gives you guidance on what goes in which layer, instead of shipping one giant container that gets mutated until no one knows what’s on it.”
How it works
From simulation to one user’s car
Each user trains a driving policy, checks it in simulation, then sends it to their own car.
- TrainWorkstation
- ValidateSimulated car
- DeliverPeridio
- DriveUser’s car
Training a driving policy in Isaac Lab, then driving it on new tracks 01 · Train · Workstation
Train in simulation
A user starts a run from the web UI. On an RTX 4090 workstation, Isaac Lab trains thousands of simulated cars in parallel with reinforcement learning.
- After training
- Driving policy
- Where
- GPU workstation · Isaac Lab
The real track, rebuilt from the car’s lidar, where the same policy drives a simulated car first 02 · Validate · Simulated car
Check it before it drives
The policy is tested on a simulated car running the same Isaac ROS nodes as the real one. If it fails here, it isn’t ready for the track.
- After validation
- Validated policy
- Where
- Simulated car · Isaac ROS
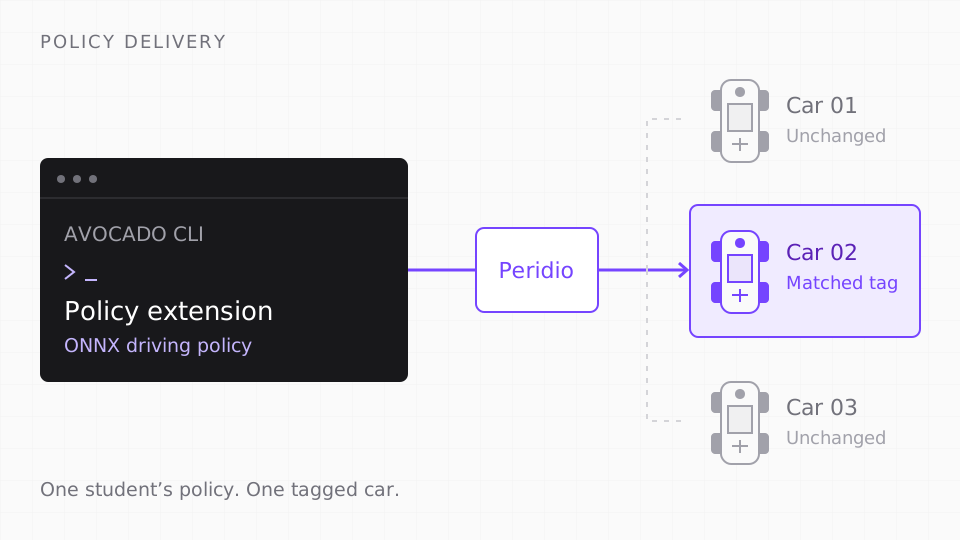
The policy extension goes only to the car with the matching user tag 03 · Deliver · Peridio
Send it to the right car
The Avocado CLI packages the policy as an extension. Peridio delivers it only to the car tagged for that user.
- Packaged for delivery
- Avocado extension
- Where
- Development machine · Avocado CLI + Peridio
04 · Drive · User’s car
Run on real hardware
The car picks up the policy automatically. The ONNX file runs inference on the Jetson, with no cloud connection.
- Running on the Jetson
- ONNX inference
- Where
- User’s car · Jetson Orin Nano
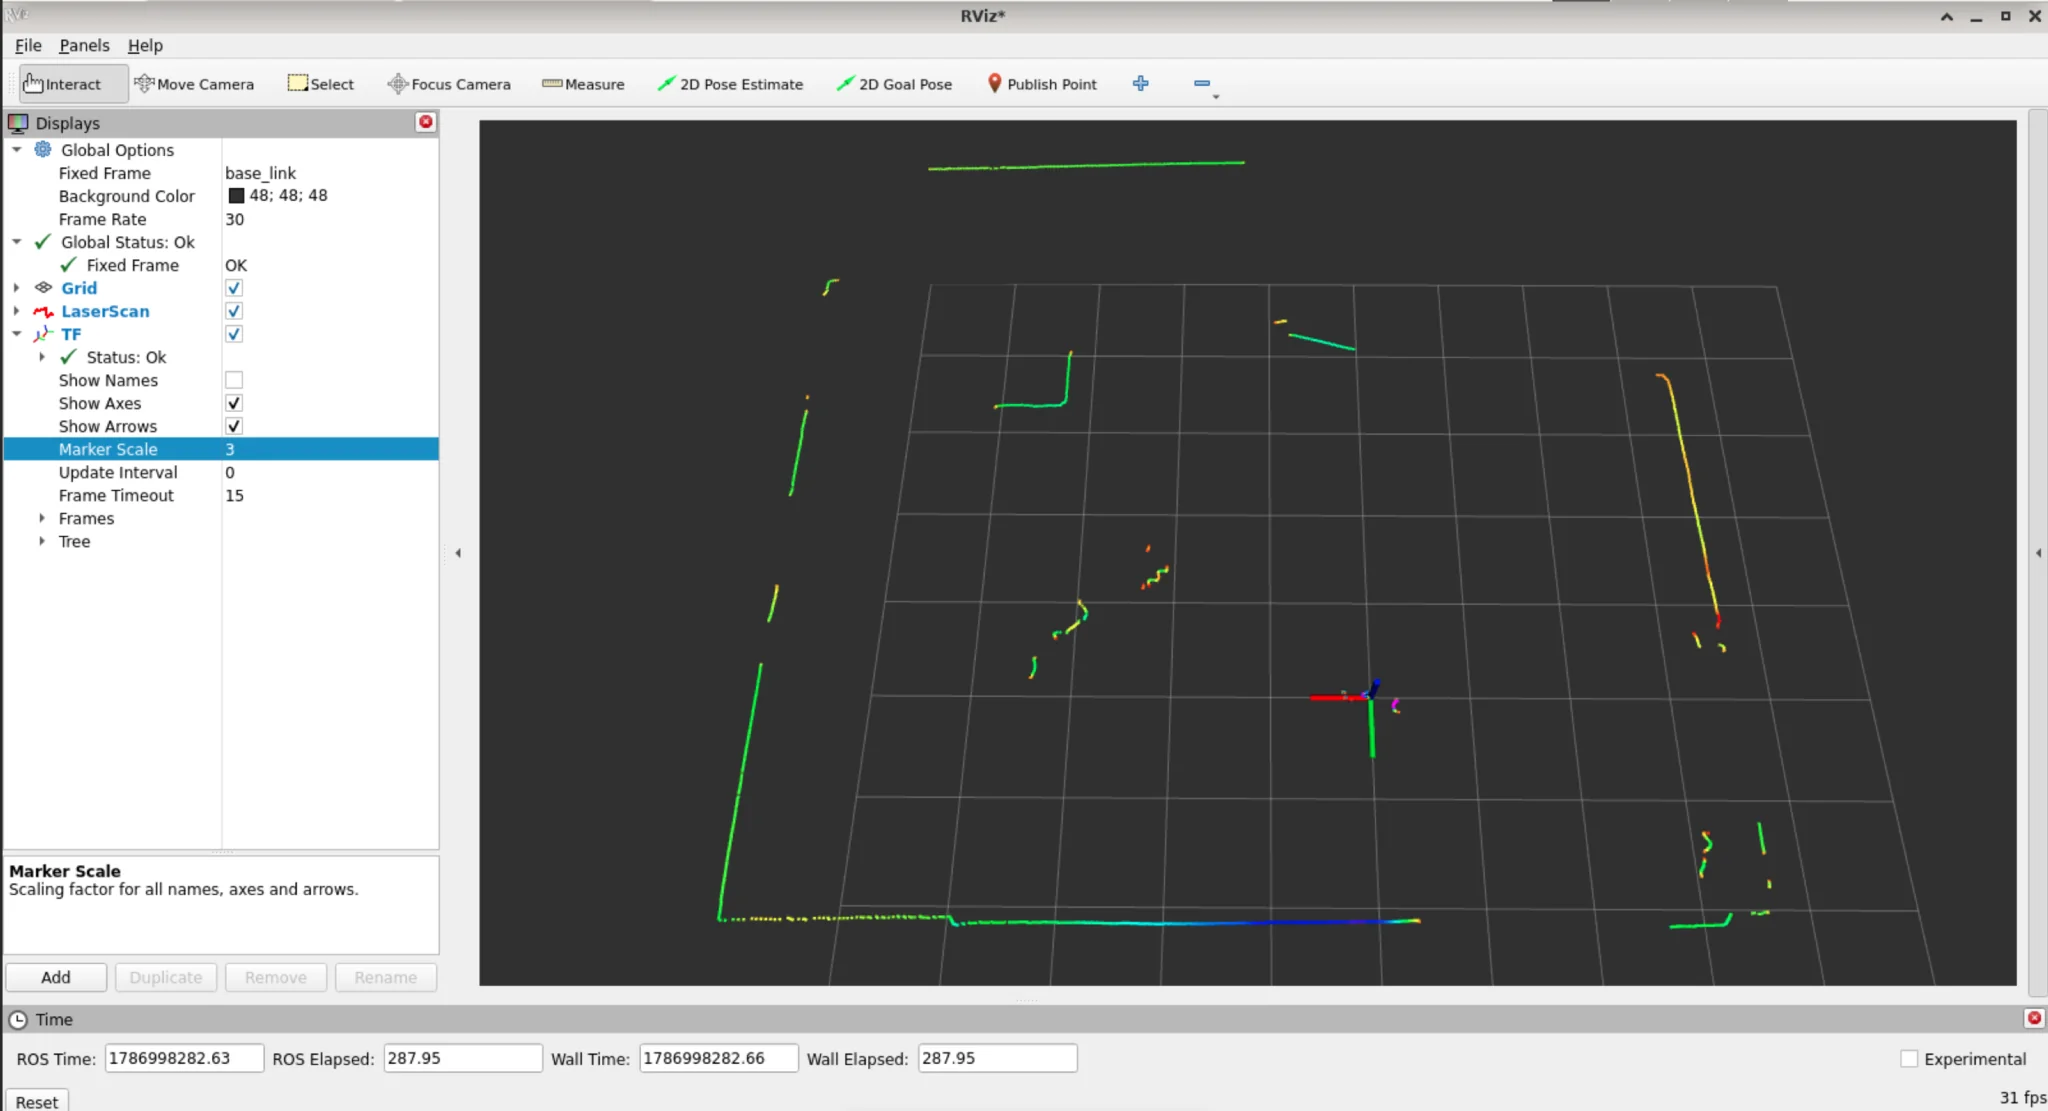
01 · LiDAR · laser scan in RViz/goat/hardware/lidar/scan 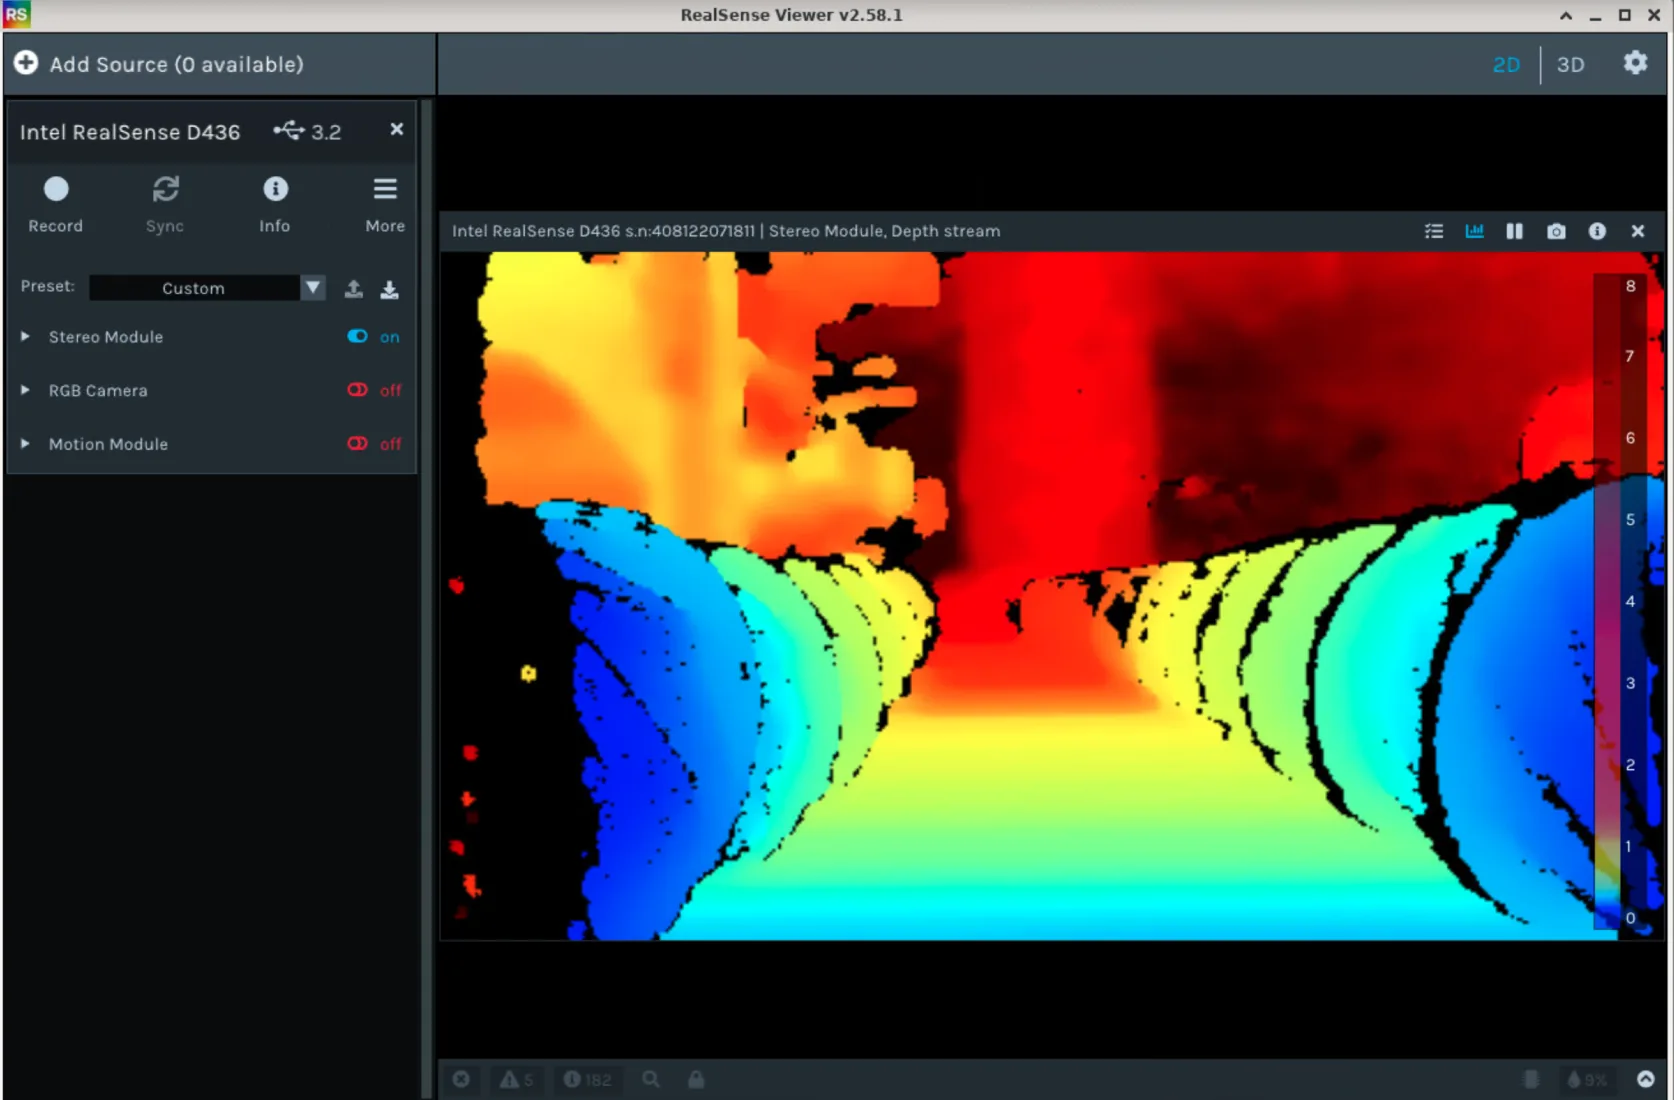
02 · Depth · RealSense ViewerIntel RealSense D436 03 · Track · laps on the office test track 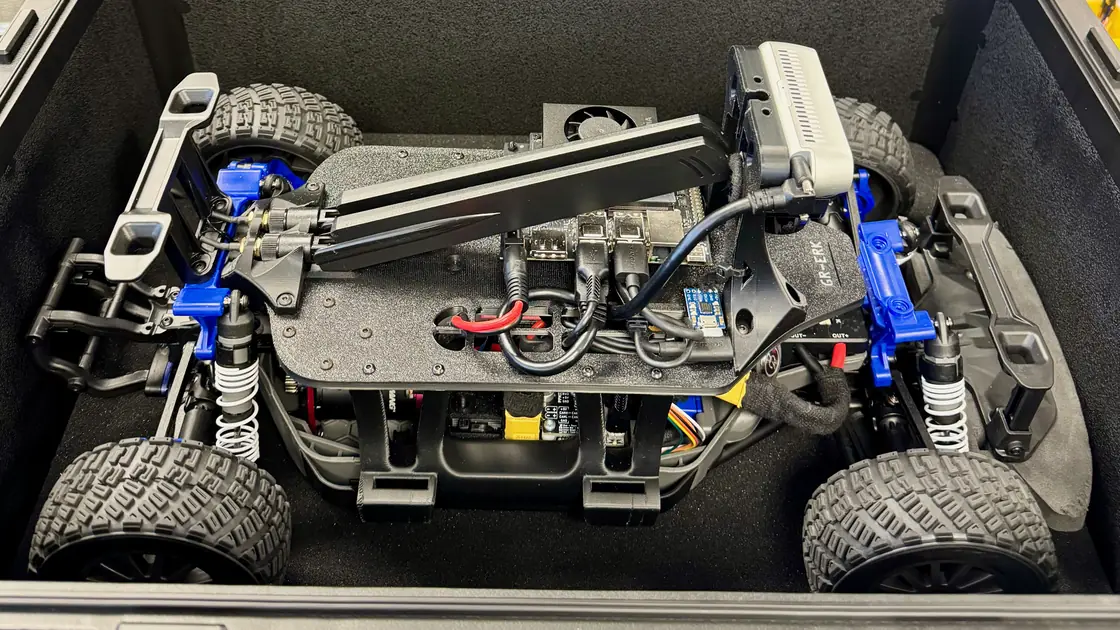
04 · Car · GOAT Racer 3 in its caseJetson Orin Nano
What actually ships
A new driving policy, without a reboot
Only what changed goes over the air: a roughly 400 KB ONNX file. The base OS and the rest of the stack stay untouched, and the car keeps running while the update lands.
The boot path uses NVIDIA’s A/B boot control. The rest of the disk holds persistent data and extensions on Btrfs. An extension-only update needs no reboot and no A/B switch.
Jetson disk
Boot slot A
base OS, active
Boot slot B
base OS, standby
Btrfs
persistent data and extensions
policy update
- UntouchedA/B boot control never runs. No slot switch, no reboot.
- UntouchedData stays where it is.
- Only this changesOne file lands while the car is running.
GOAT Racer 3 results
“The more I use Avocado, the more I appreciate it.
Foundationally, the base is there and I’m not touching it.A
I only put things on top,B so it feels much more stableC
than my Docker flows ever did.”
| Before | With Avocado OS | |
|---|---|---|
| Result AProvisioning a car | ~3 hours, SDK Manager on a dedicated Ubuntu host | 10 minutes |
| Result BPolicy update | Rebuild and ship a Docker container | ~400 KB extension, targeted to one car |
| Fleet consistency | Drift past three cars | Every car on an identical, reproducible base |
| Result CUptime | Reboots on update | Days without a reboot across policy updates |
| Remote access | In-house tooling | Built-in secure tunnels from the fleet view |
What’s next
What’s next for GOAT Racer 3: JetPack 7.2 over the air, and more Jetson modules
Cryptide Research begins shipping GOAT Racer 3 cars and a hands-on curriculum this fall. Two upgrades are already in motion.
JetPack, over the air
JetPack 6.2toJetPack 7.2
On Peridio’s 2026 feeds. The team called it impossible on its old stack.
Policy build time
About a minutetoSeconds
An OTA-only build path Peridio is adding.
Hardware target
Jetson Orin Nanoto[CONFIRM: Jetson Orin NX · Jetson AGX Orin · Jetson AGX Thor]
Avocado OS abstracts the board, so the same configuration can target any supported Jetson module with a one-line change.
On the show floor
GOAT Racer 3 at Actuate and Embedded World North America
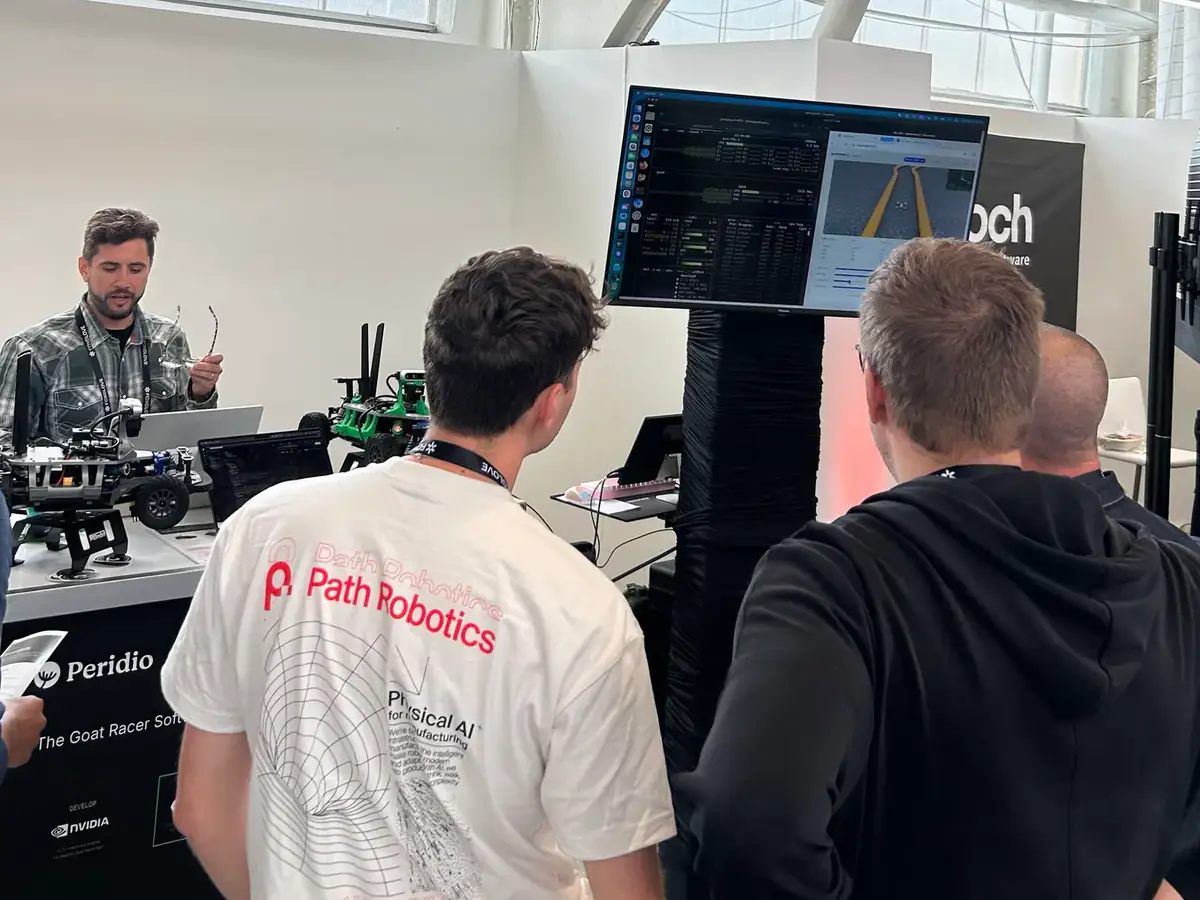
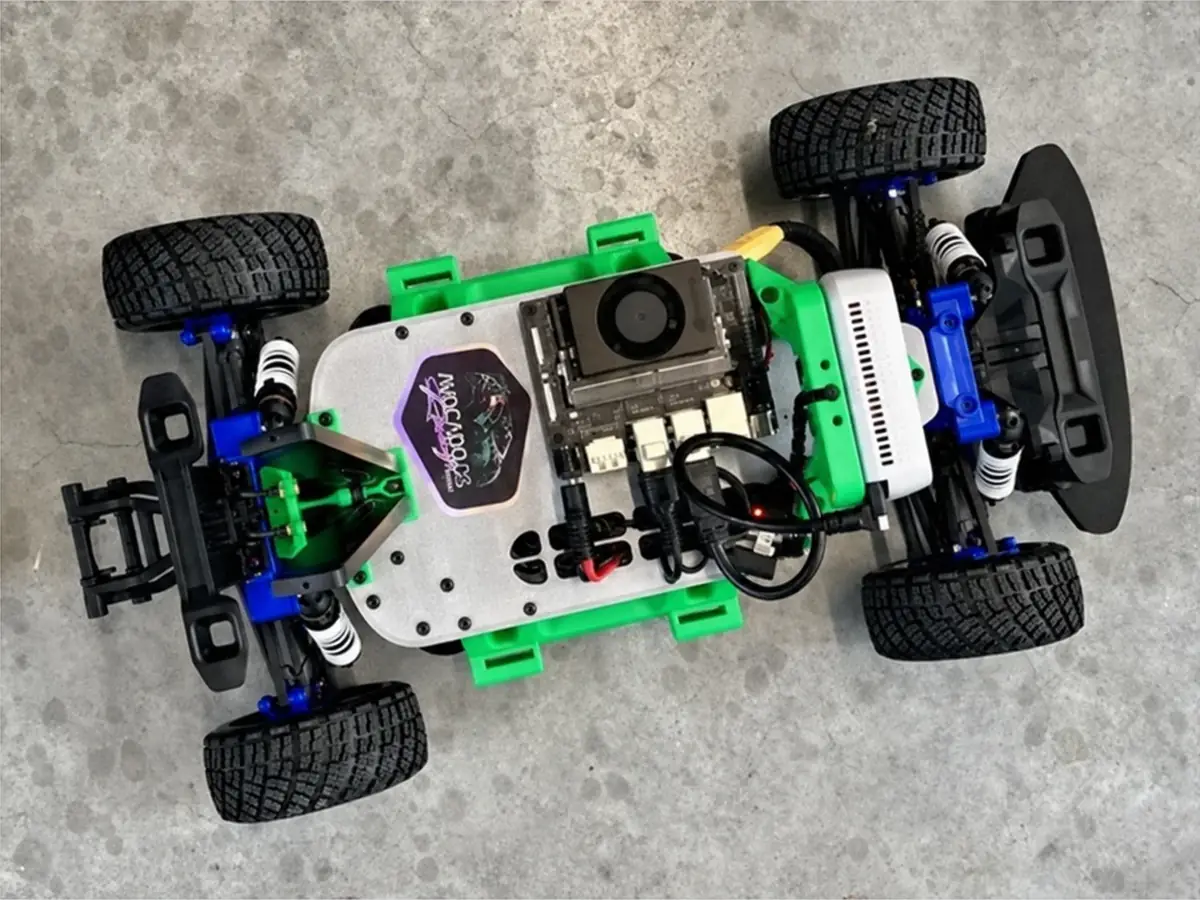
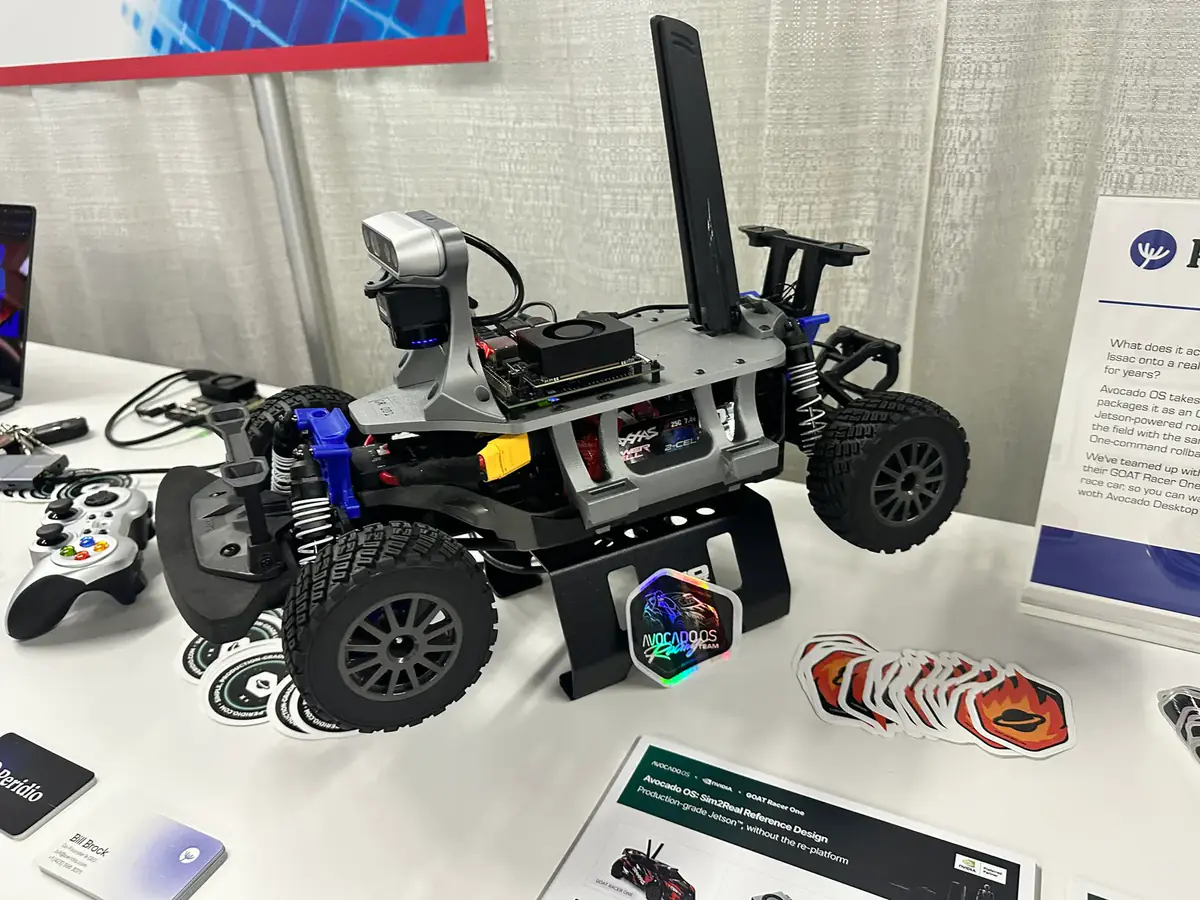
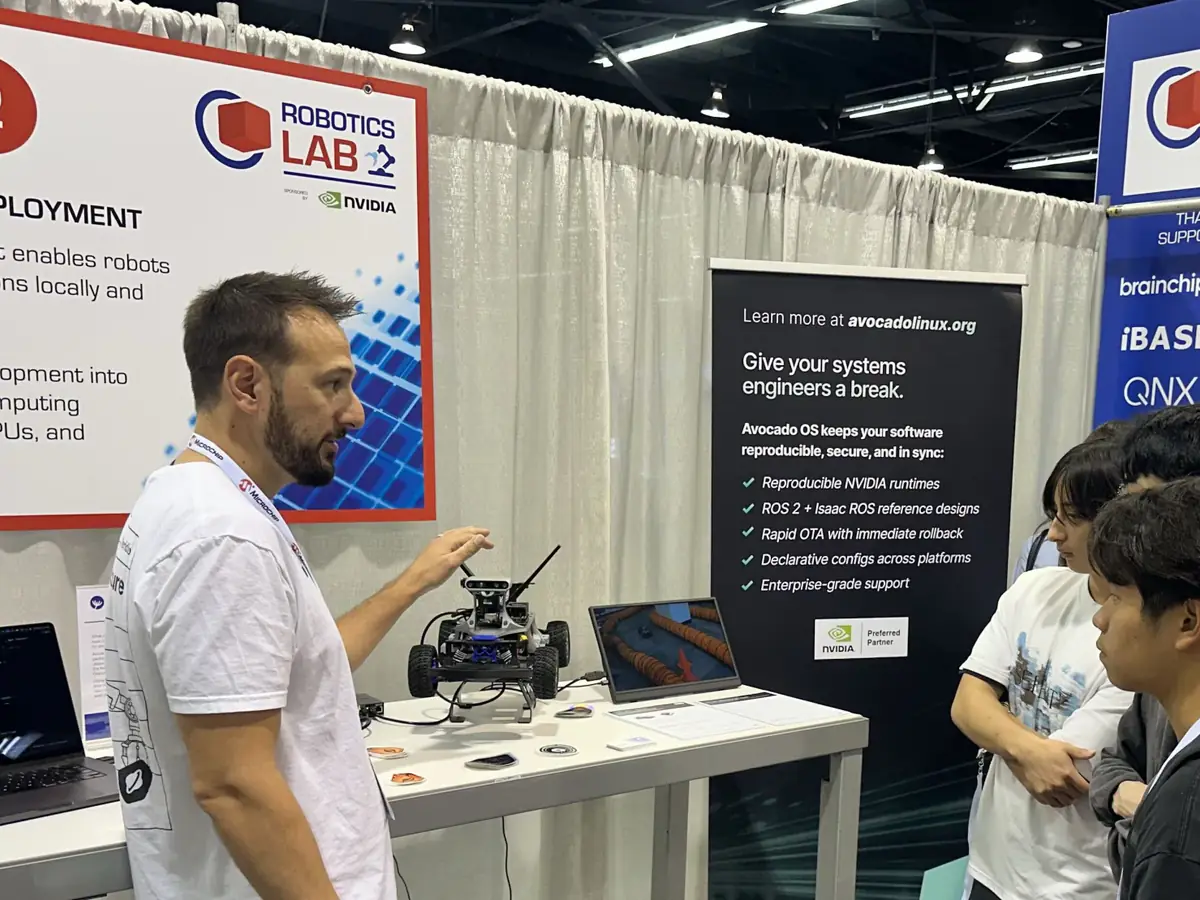
Peridio brings the car to robotics shows so engineers can watch the whole loop on real hardware: a policy trained in Isaac Sim, deployed to the Jetson as an OS extension and updated over the air, with Avocado OS managing the car.
Ride along
Three ways into GOAT Racer 3
Everything on this page runs on a car you can drive. Cryptide Research sells the cars, runs the course and brings workshops to your group.
Visit cryptide.com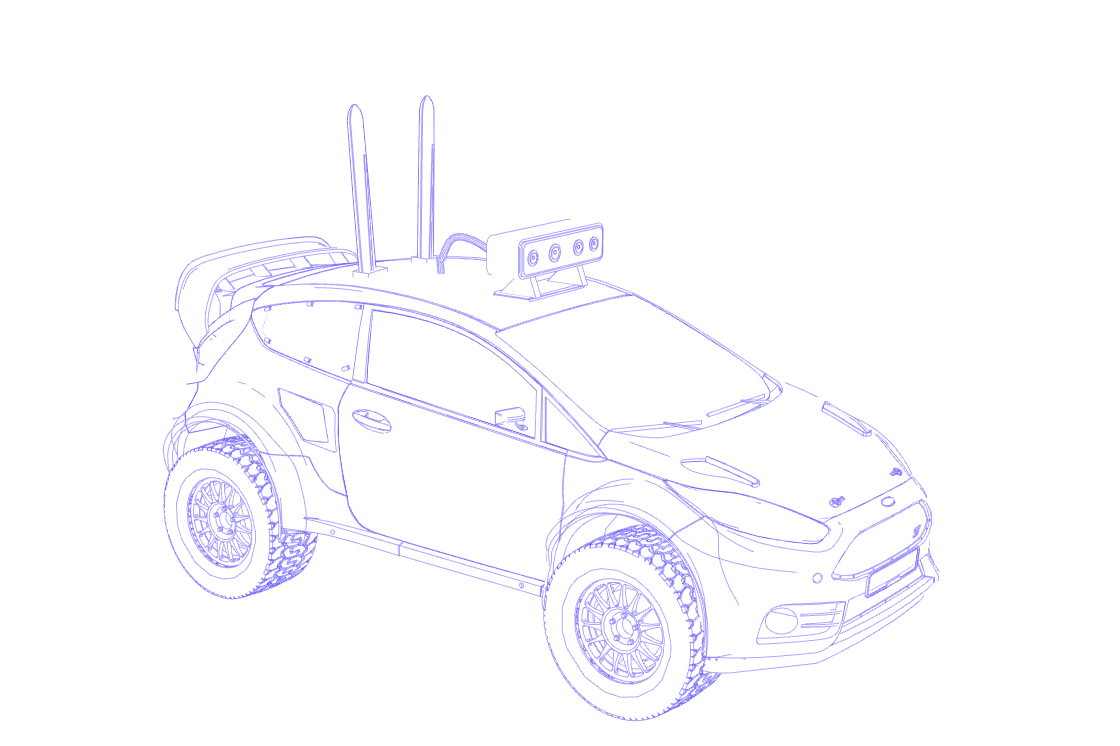
The course
Learn sim-to-real, free
Start the courseA guided course at goatracer.ai: drive, simulate, train and race. The first labs need no account.
The car
Put a GOAT Racer 3 on your track
Buy a carThe Jetson Orin Nano car from this story, with the course and the training source code. A lighter LEAN build has an upgrade path to the full car.
See GOAT Racer 3 LEANThe workshop
Bring it to your class or team
Plan a workshopAn in-person workshop for your group. The team brings the cars, the course and the cloud tools.